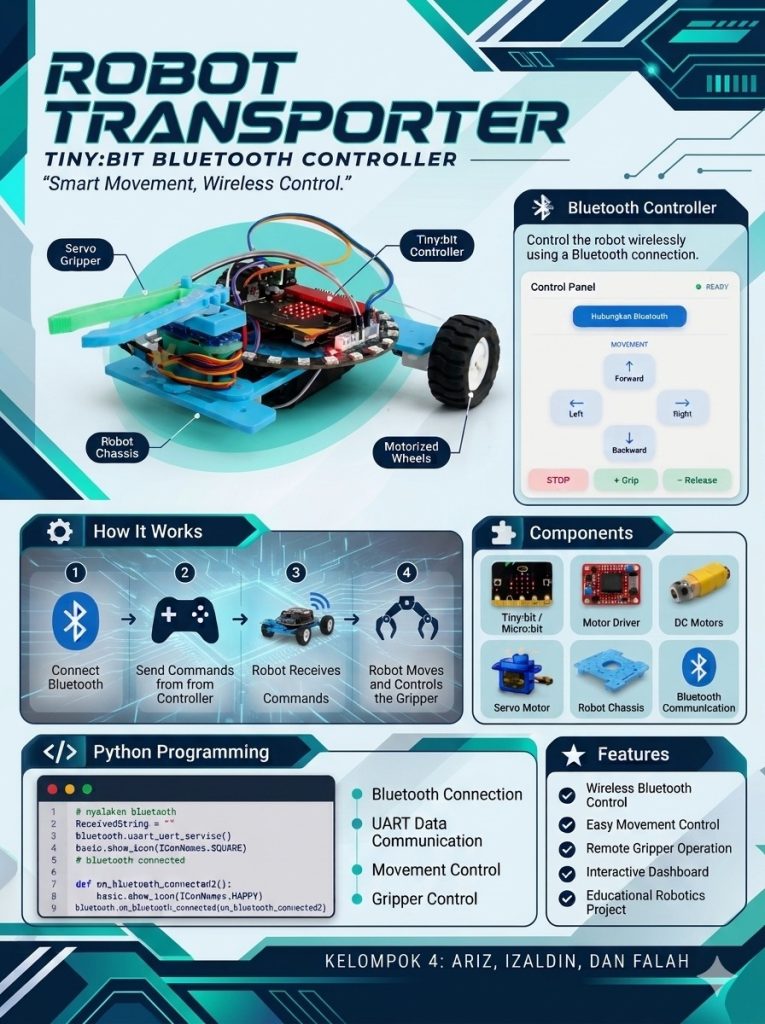
Robot Transporter is a project that uses a Tiny:Bit robot controlled through a Bluetooth connection. This robot can move forward, backward, left, and right using commands from a Bluetooth controller. The main idea of this project is to create a robot that can be controlled wirelessly without needing a direct connection.
Besides moving in different directions, the robot also has a servo gripper that can grab and release objects. We use a Micro:bit, motor driver, DC motors, servo motor, and robot chassis to build the system. The controller has several buttons for movement, stopping, and controlling the gripper, making it easier to operate the robot.
For this project, we used Python programming to connect the Bluetooth controller with the robot and send commands through UART communication. Through this project, we learned more about programming, Bluetooth communication, and how different components work together. It was a fun experience because we could build, control, and test our own robot.
 loading . . .